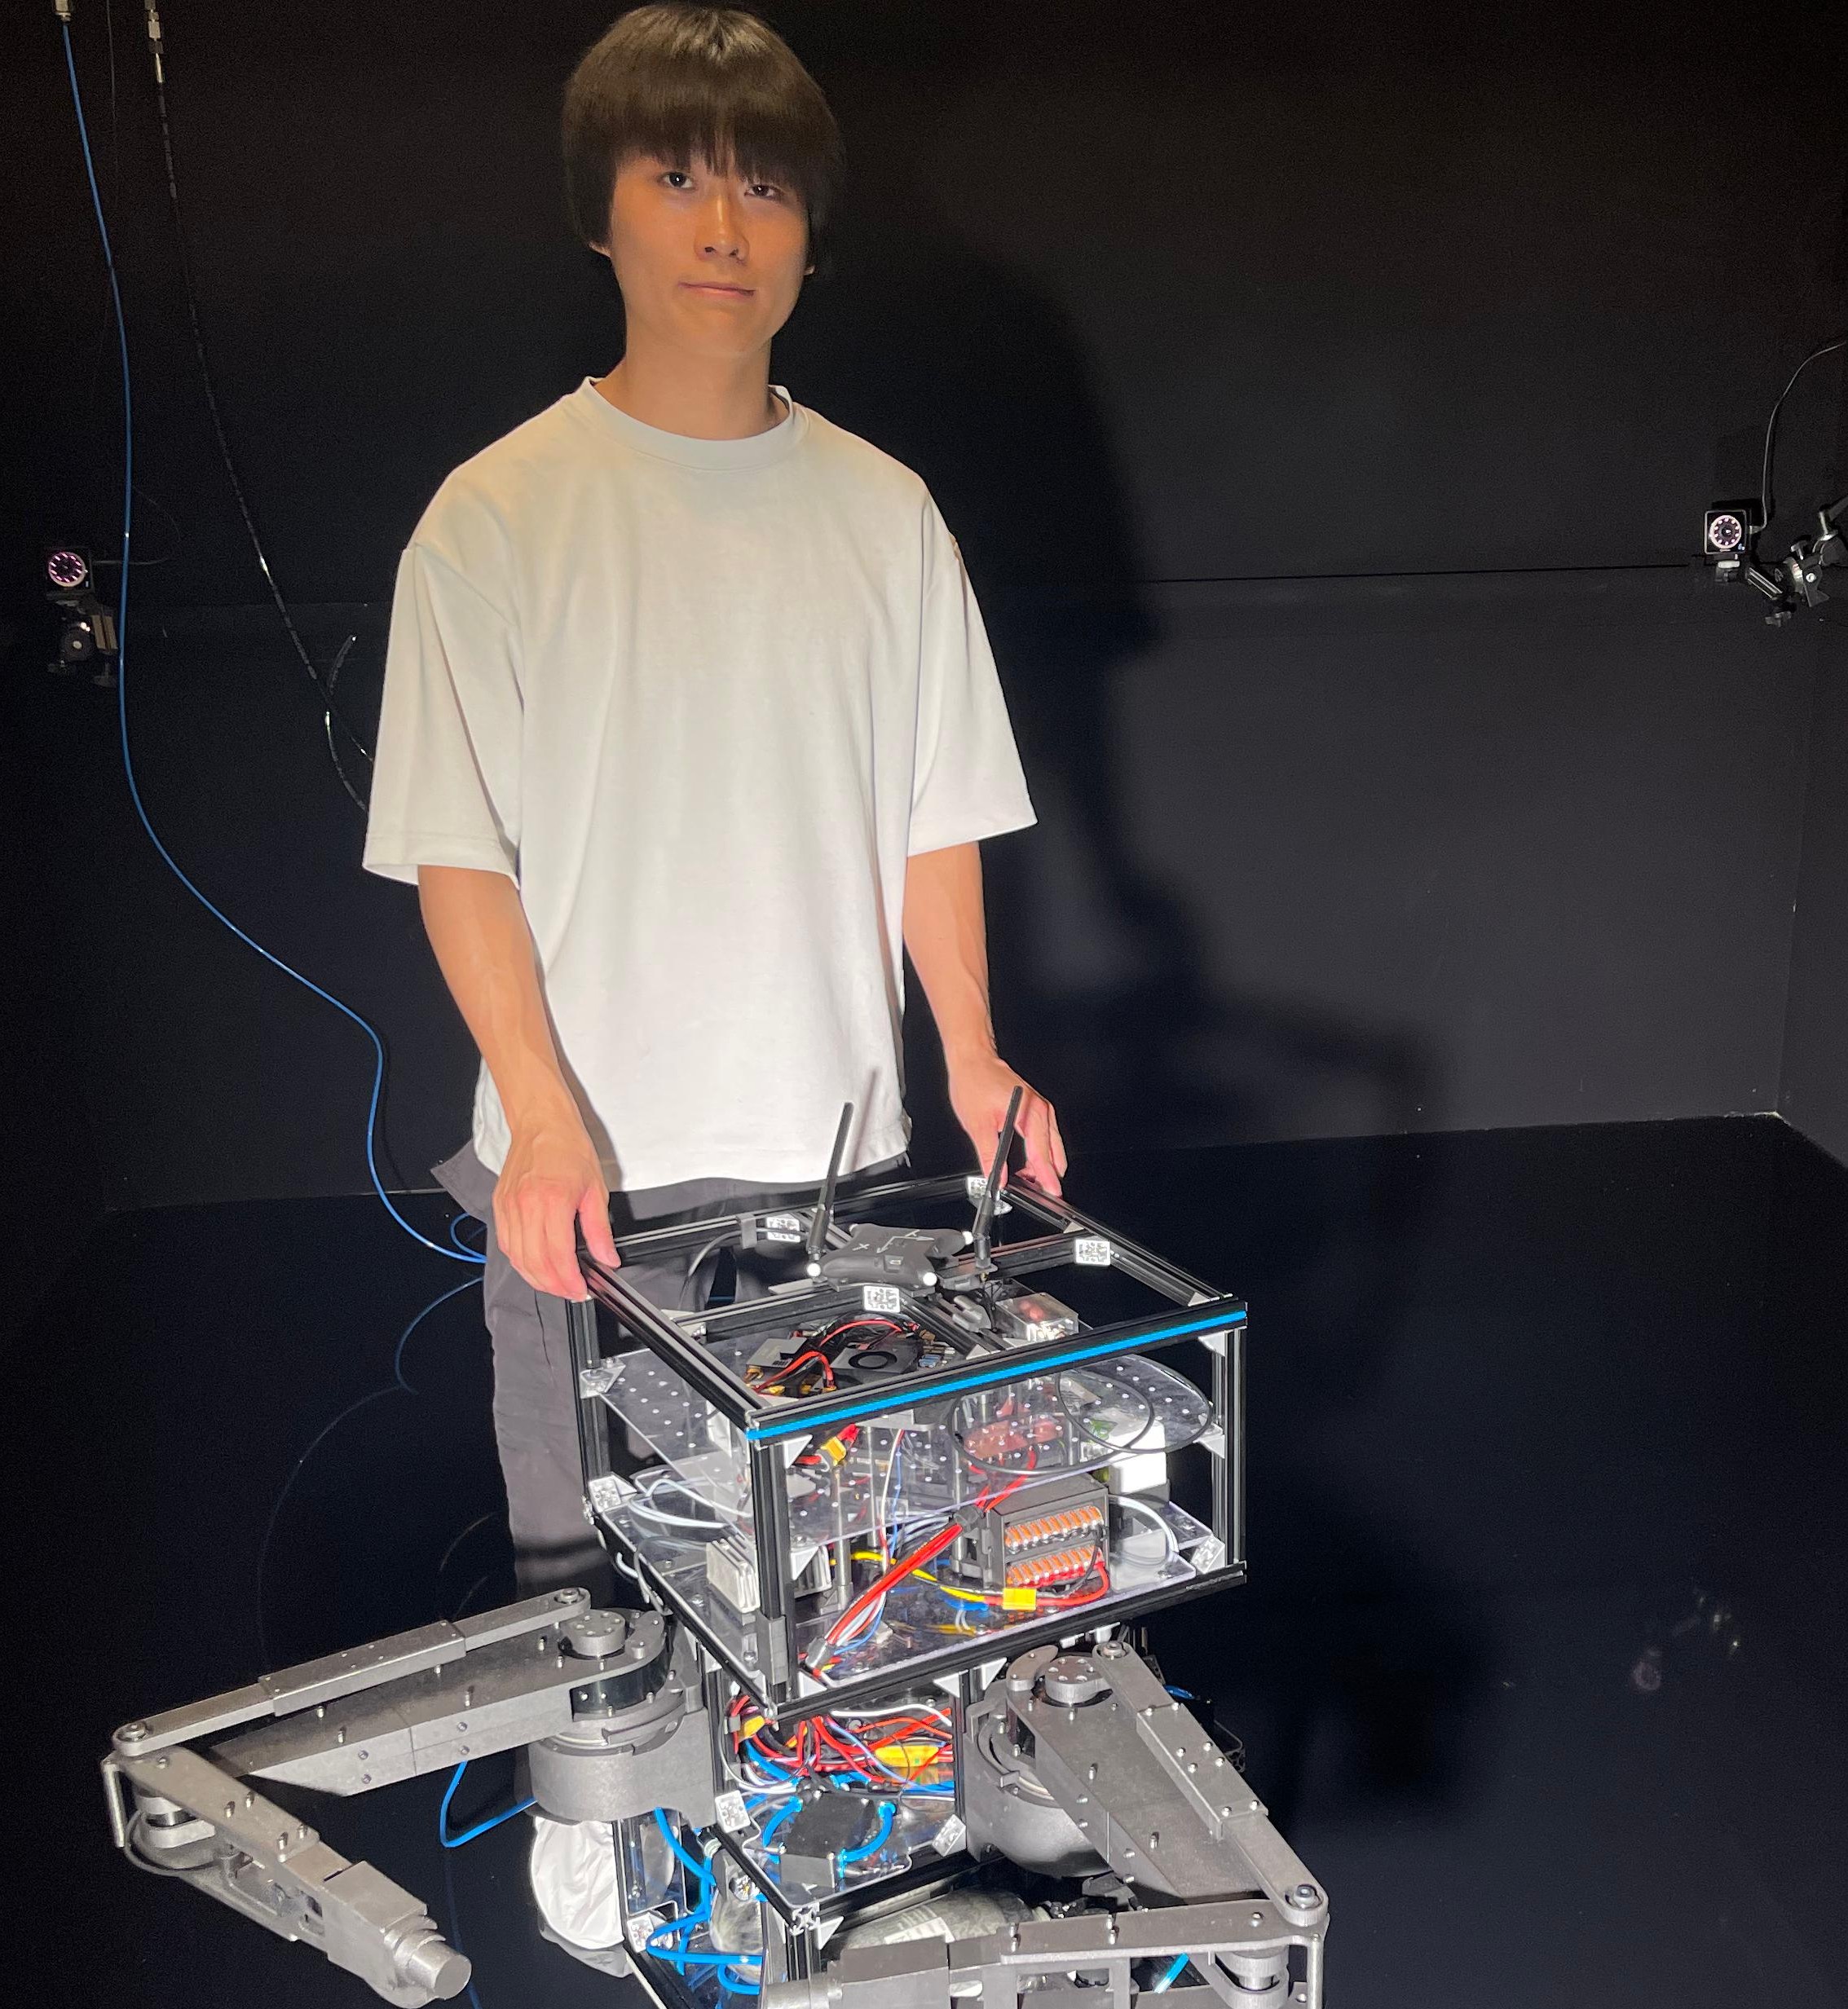
スラスタ機構およびマニピュレータを搭載した軌道上ダイナミクス模擬を実現する二次元空気浮上ロボットの設計
Published in ロボティクス・メカトロニクス講演会 2026 (ROBOMECH 2026), 2026
This paper presents the conceptual and system-level design of a planar floating robot (PFR) equipped with compressed-air thrusters and a robotic manipulator for ground-based emulation of free-floating spacecraft dynamics.
The proposed platform integrates an air-bearing mechanism, an onboard pneumatic propulsion system, a robotic manipulator, and sensing capabilities to reproduce planar translational and rotational motion under near-frictionless conditions.
The design provides an experimental foundation for future validation of proximity operations, spacecraft capture, and detumbling strategies, including multi-robot cooperative experiments.
Recommended citation: 飯塚健太, 片男浪輝大, 内田亮慈, 竹花佳祐, 古田雄大, 齊藤拓実, 桒原聡文. (2026). "スラスタ機構およびマニピュレータを搭載した軌道上ダイナミクス模擬を実現する二次元空気浮上ロボットの設計." ロボティクス・メカトロニクス講演会 2026 (ROBOMECH 2026).
Download Paper