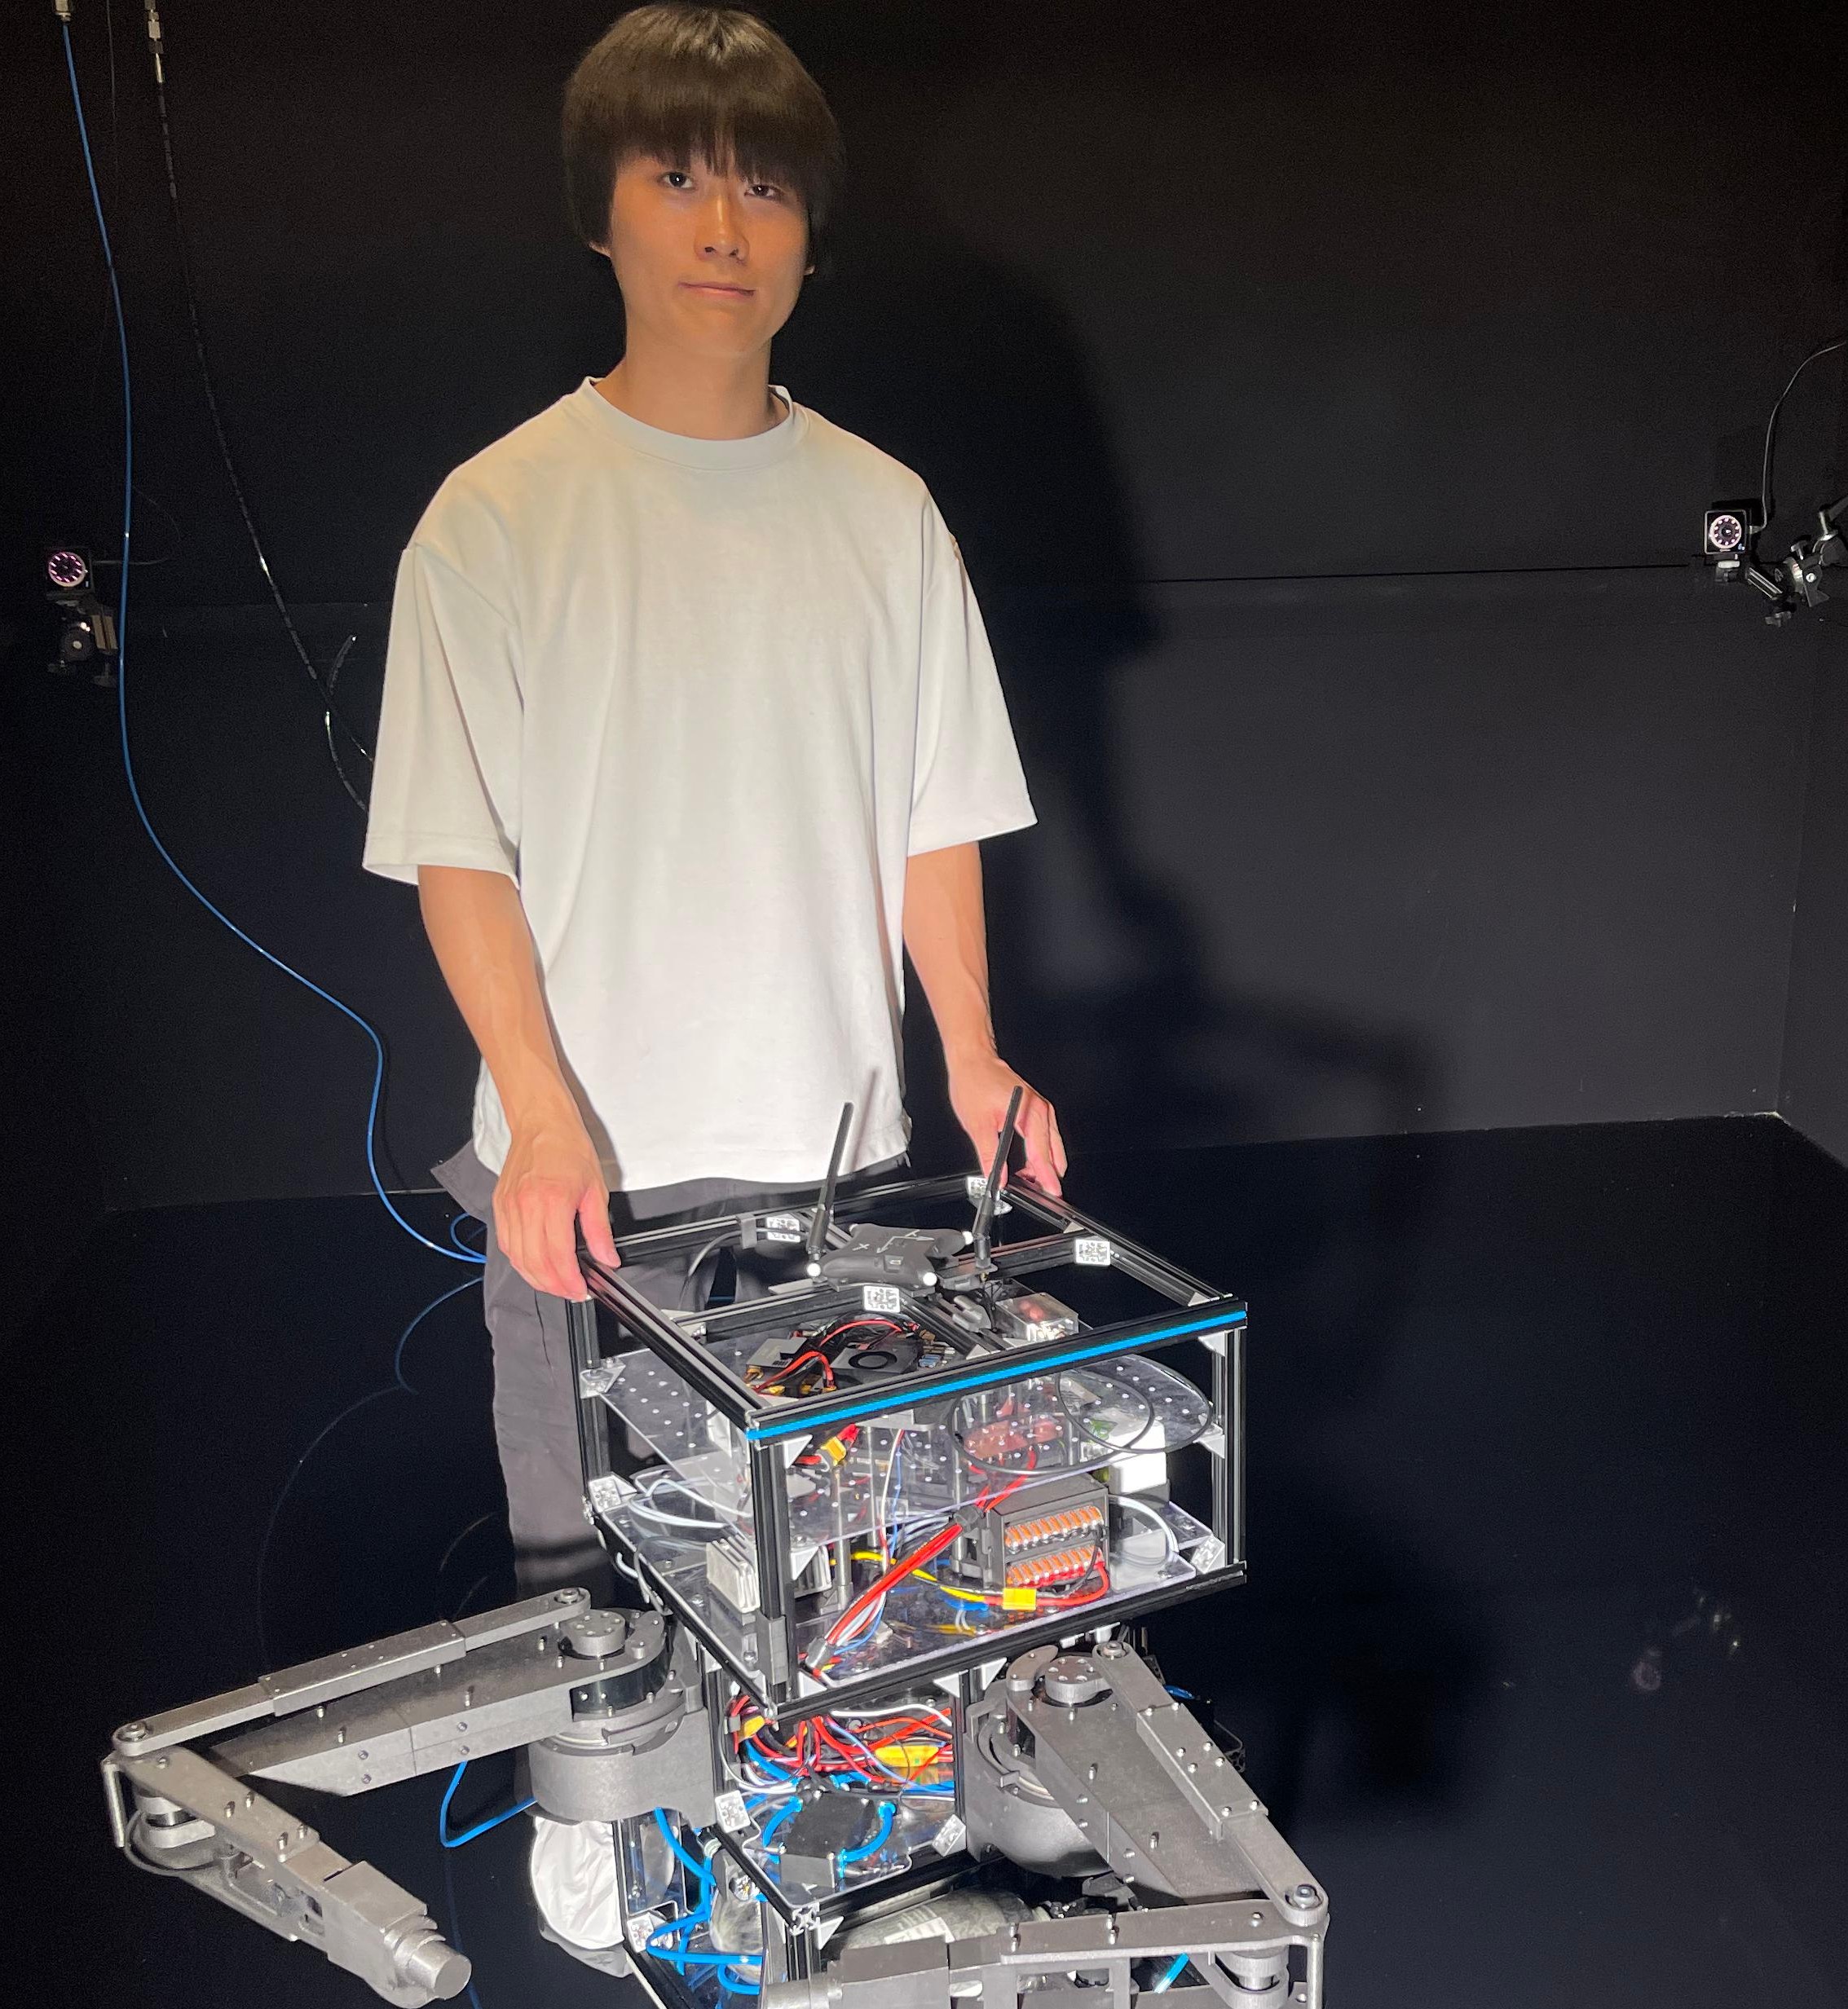
軌道上ダイナミクス模擬を実現する二次元空気浮上ロボットのための双腕マニピュレータの開発
Published in 第44回日本ロボット学会学術講演会 (RSJ 2026), 2026
This paper presents the development of a dual-arm robotic manipulator and a planar air-floating experimental platform for investigating the coupled dynamics of free-floating space robots.
The developed system integrates planar three-degree-of-freedom manipulators, six-axis force/torque sensors, ROS 2-based control, and an air-bearing mechanism to emulate microgravity conditions in a two-dimensional environment.
Experimental results demonstrate that manipulator motion induces translational and rotational reactions of the floating base, providing a foundation for future validation of generalized Jacobian-based control, coordinated manipulation, and space debris capture strategies.
Recommended citation: 片男浪輝大, 飯塚健太, 内田亮慈, 竹花佳祐, 桒原聡文. (2026). "軌道上ダイナミクス模擬を実現する二次元空気浮上ロボットのための双腕マニピュレータの開発." 第44回日本ロボット学会学術講演会 (RSJ 2026).
Download Paper