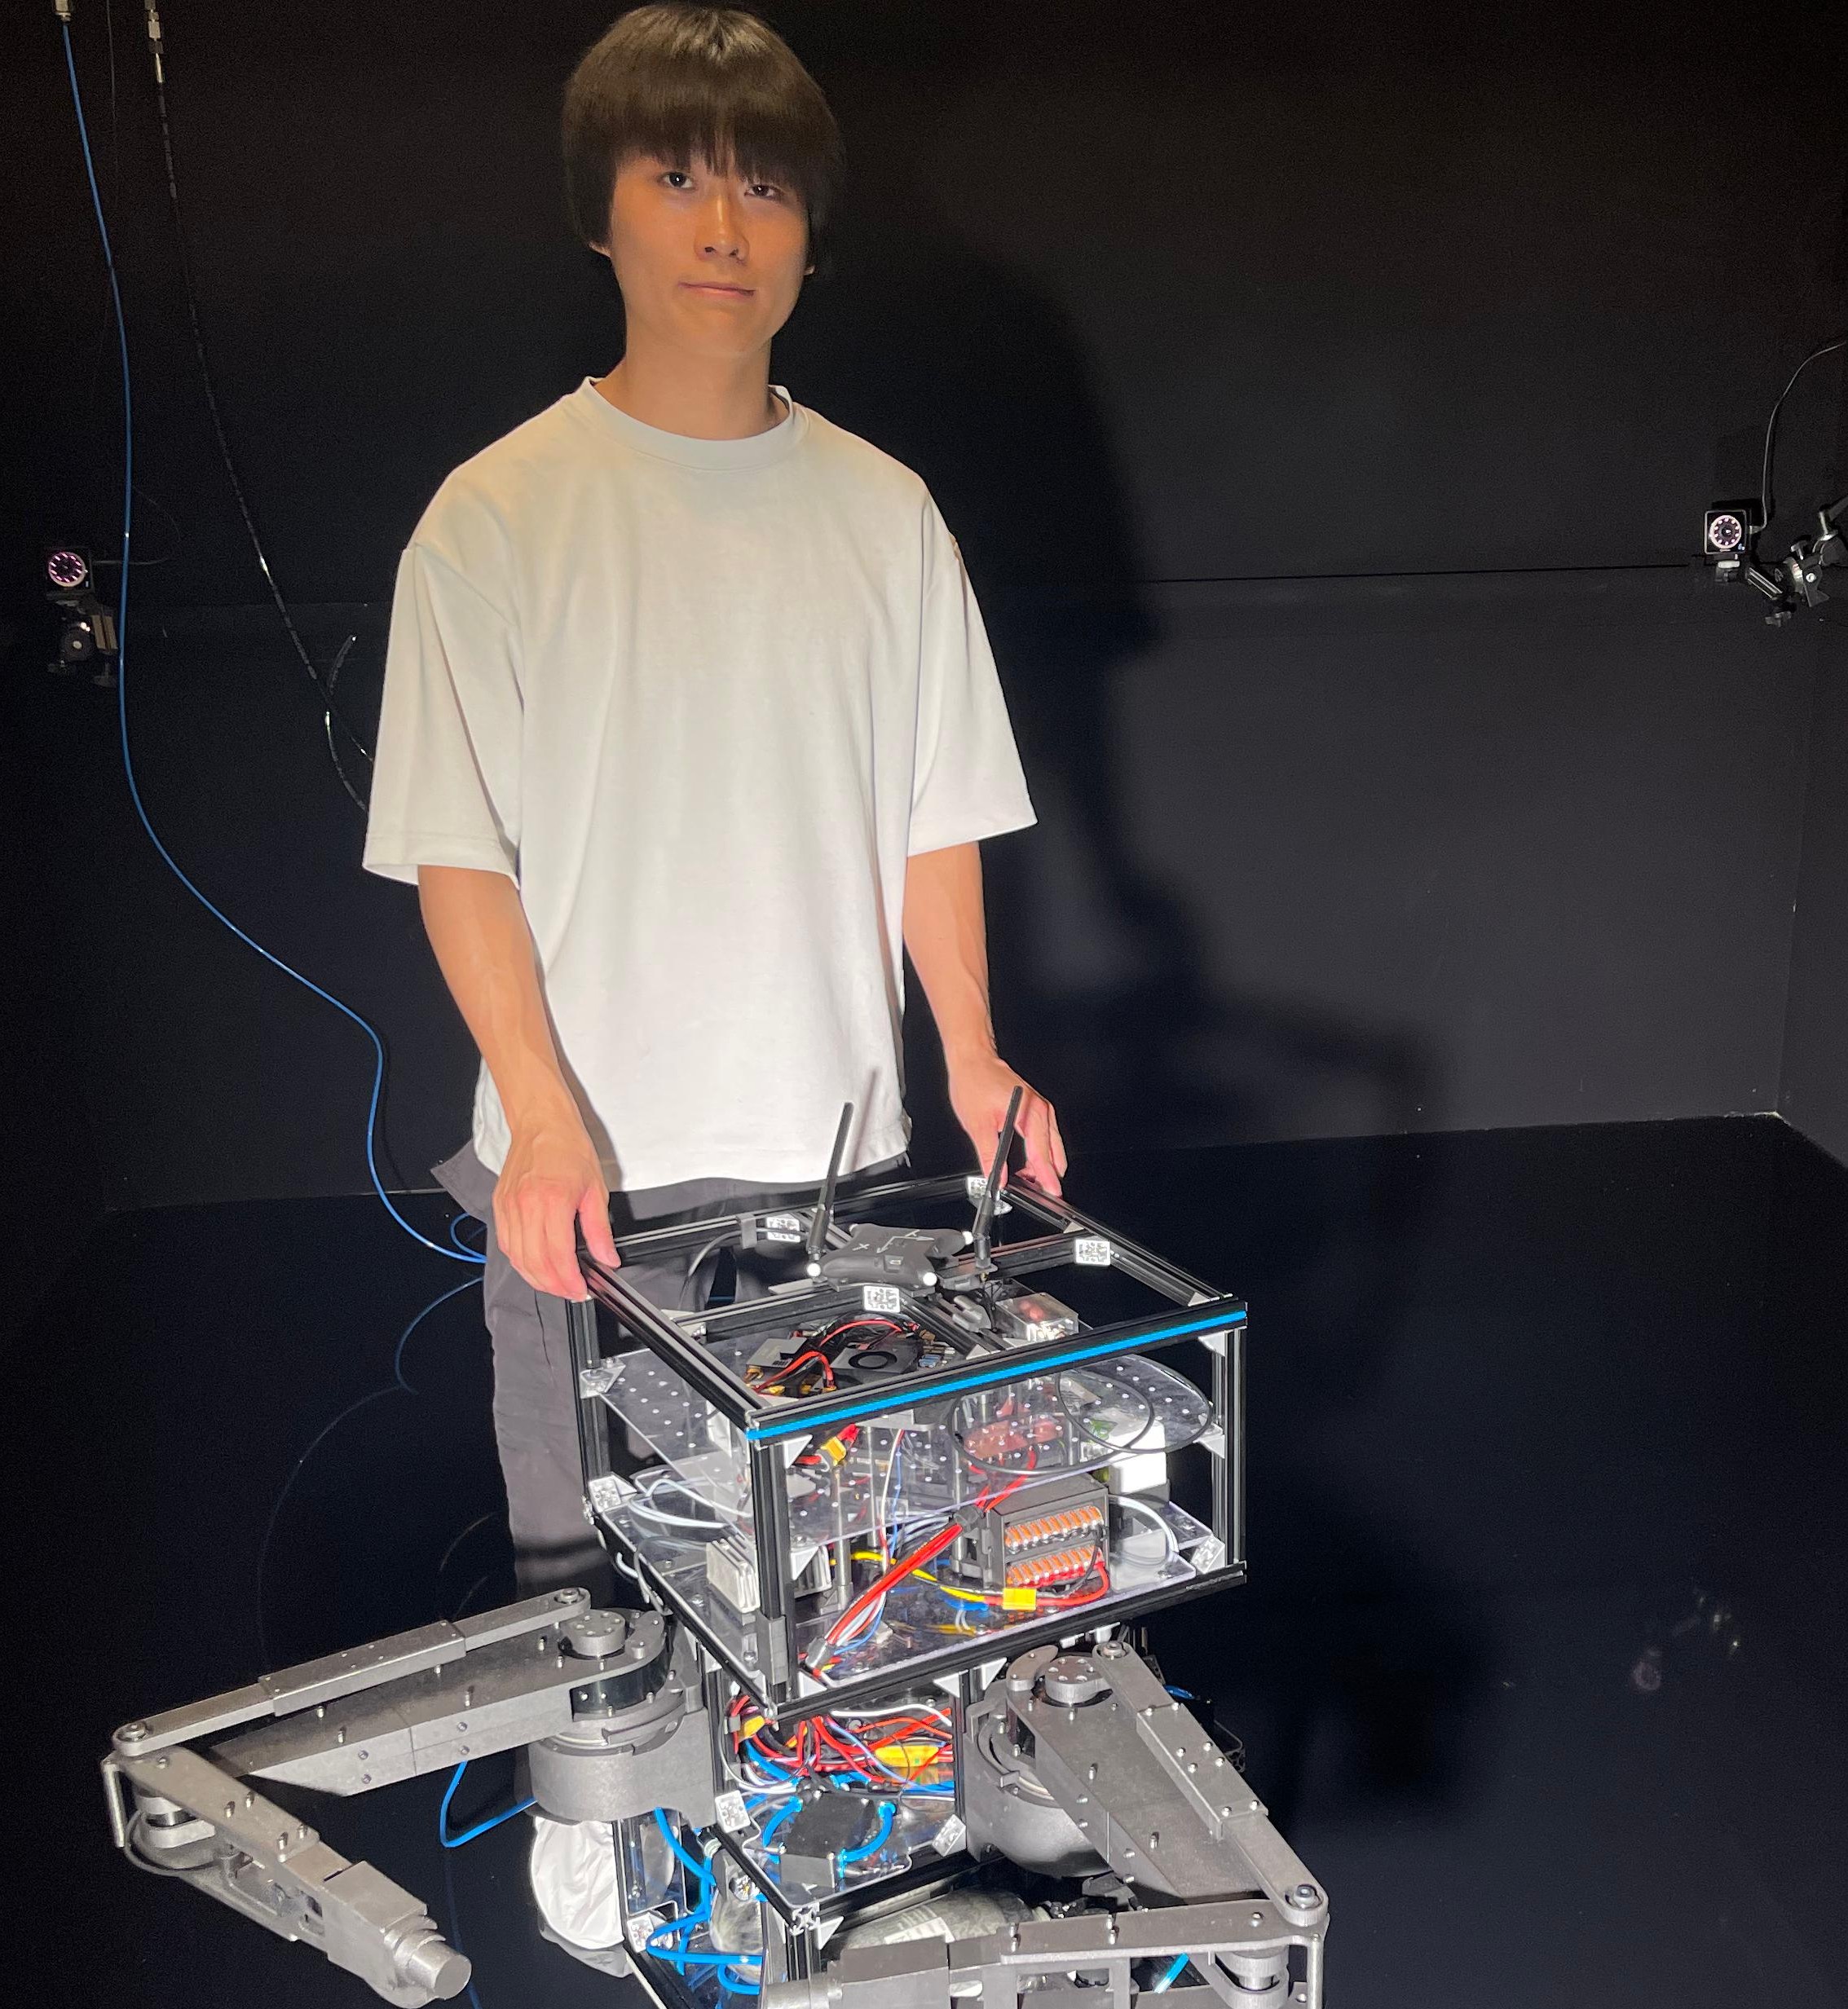
モデル予測制御を用いたスラスタ・マニピュレータシステムの協調制御
Published in 日本機械学会 東北支部講演会 (2026), 2026
This paper presents a model predictive control (MPC) framework for coordinated control of a spacecraft’s thrusters and robotic manipulator during approach and manipulation of a tumbling, non-cooperative target. The proposed approach accounts for dynamic coupling between the spacecraft base and manipulator, allowing thruster inputs to compensate for reaction forces generated by arm motion.
Numerical simulations demonstrate stable relative-motion tracking, sequential approach, and precise end-effector positioning, achieving sub-millimeter tracking accuracy for both the spacecraft base and manipulator.
Recommended citation: 片男浪輝大, 内田亮慈, 飯塚健太, 竹花佳祐, 桒原聡文. (2026). "モデル予測制御を用いたスラスタ・マニピュレータシステムの協調制御." 日本機械学会 東北支部講演会.
Download Paper