インピーダンス制御を用いた双腕ロボットによる宇宙デブリ捕獲手法
Published in 第41回日本ロボット学会学術講演会 (RSJ 2023), 2023
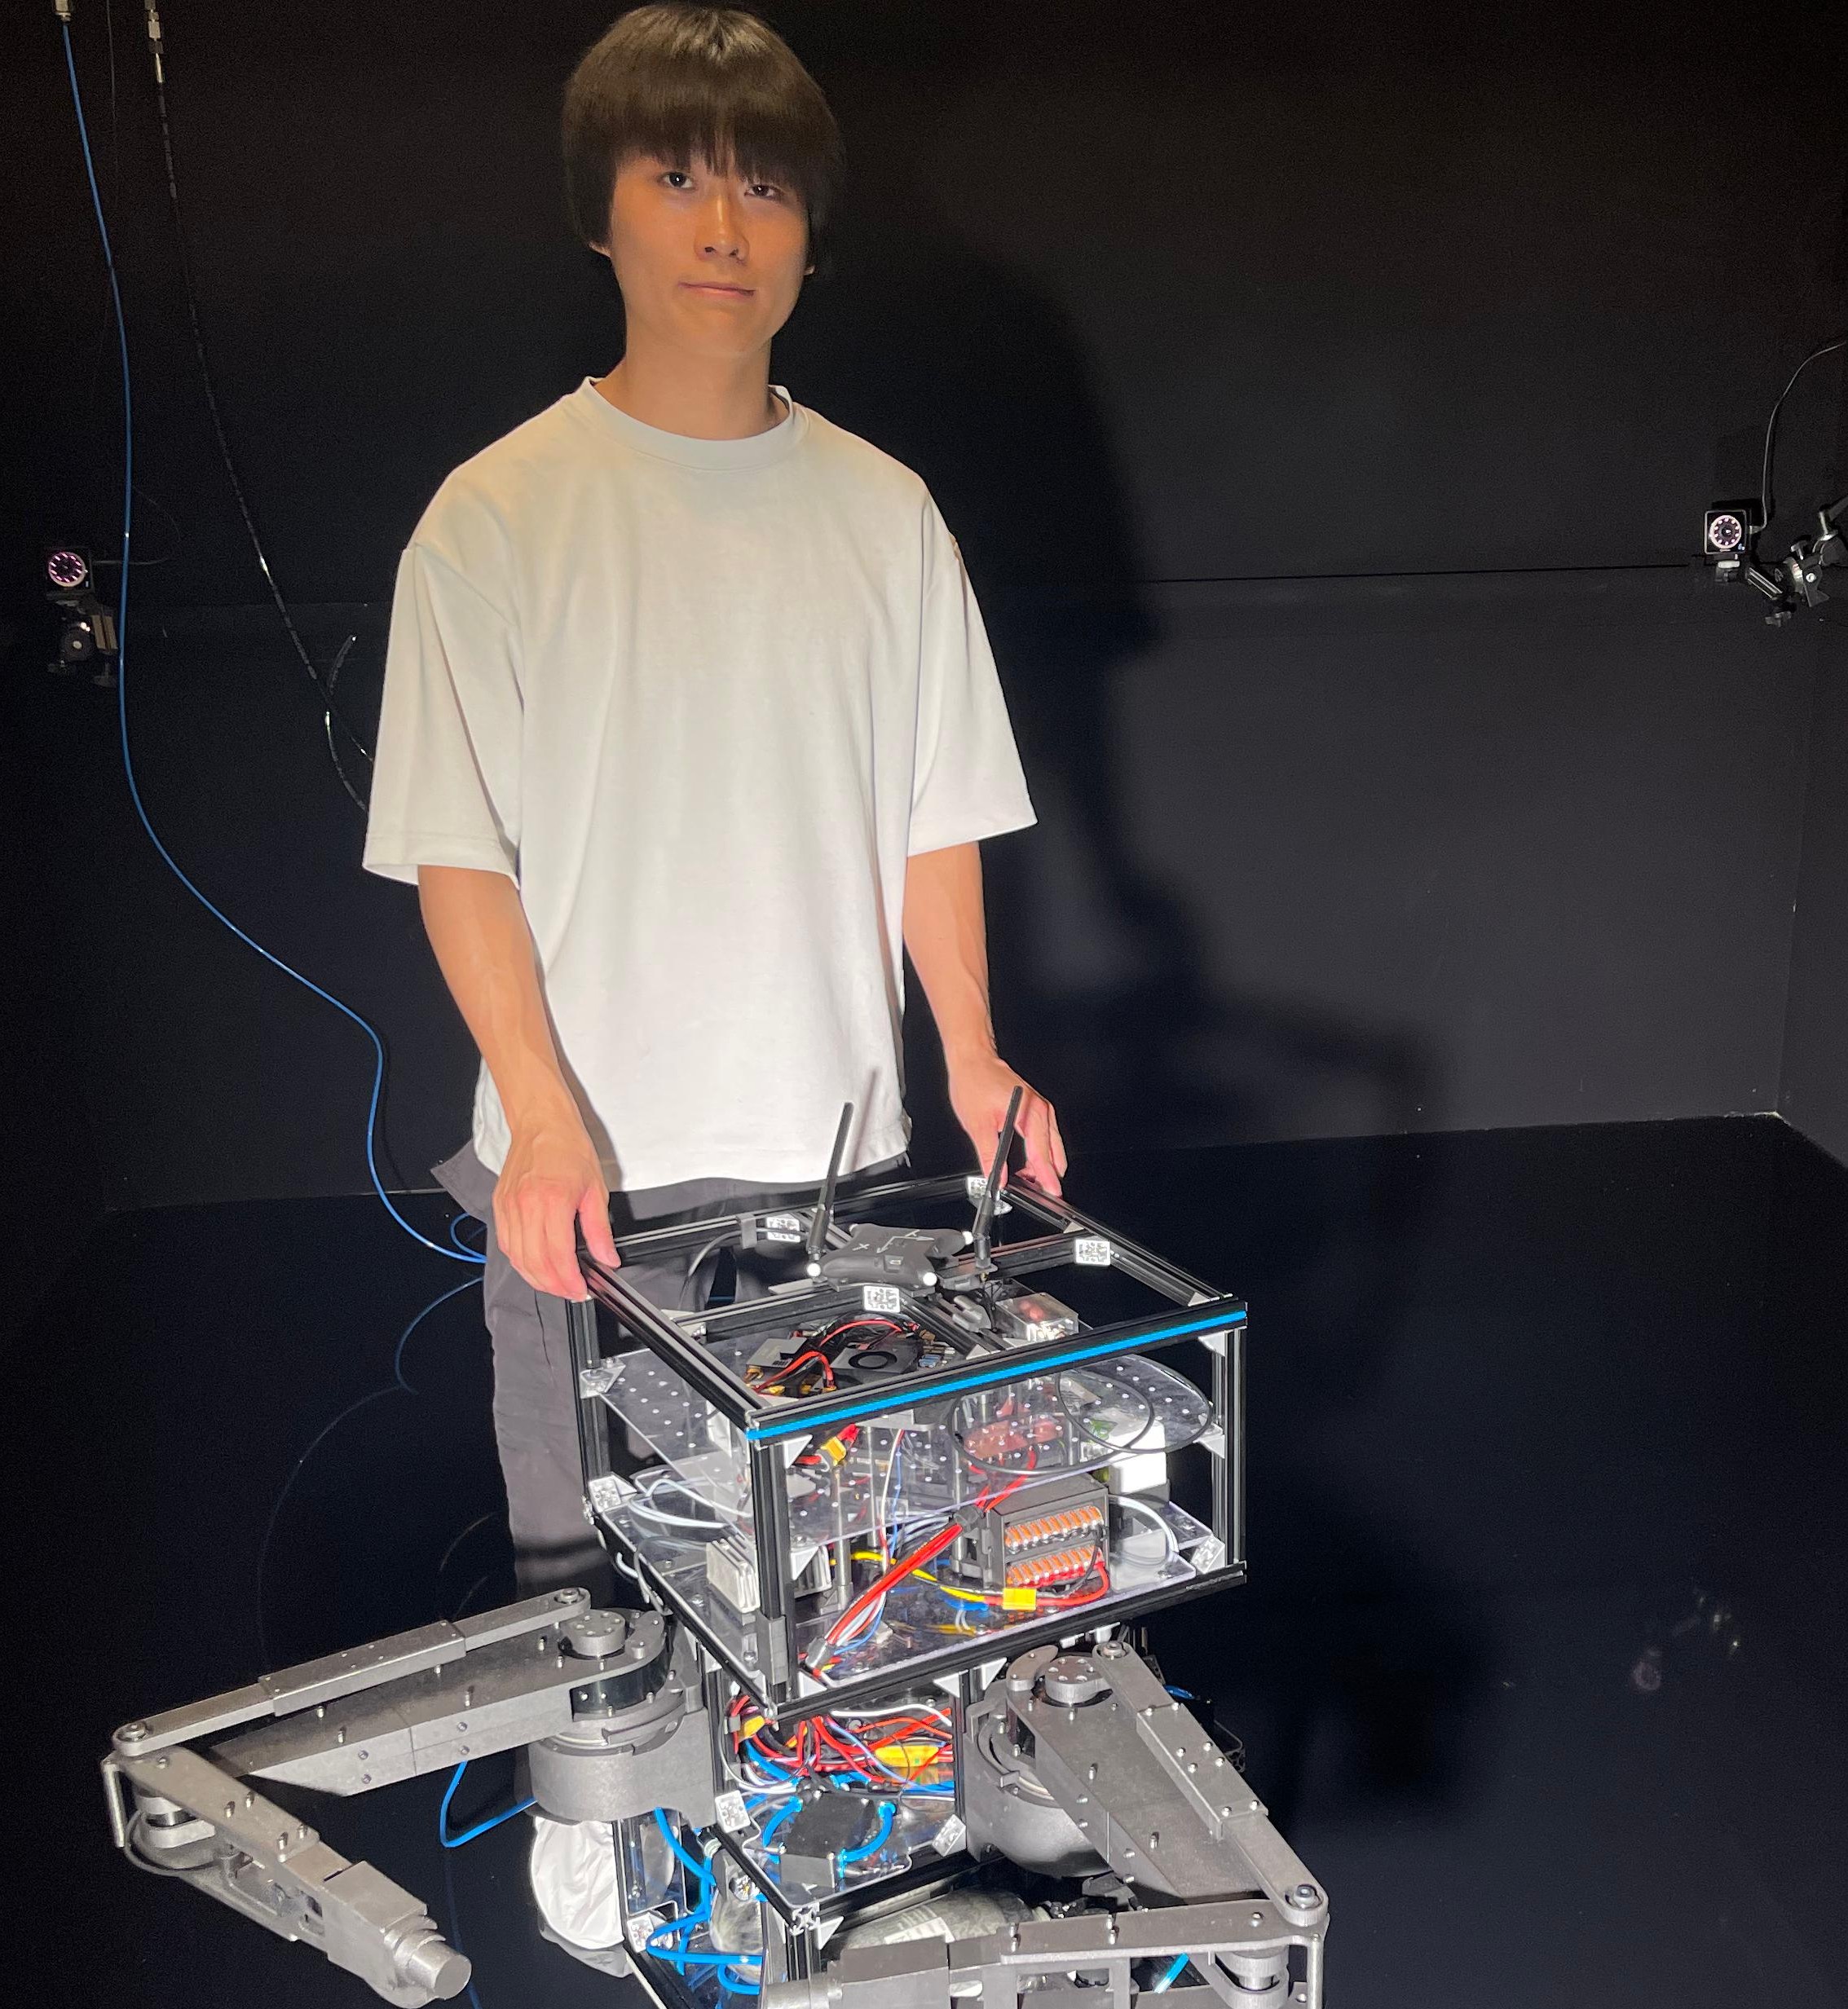
This paper proposes a space debris capture strategy for a dual-arm free-floating robot by combining impedance-controlled repeated contact with caging. The proposed method gradually reduces the rotational motion of a tumbling target before capture. Numerical simulations demonstrate a 66% reduction in peak contact force compared with direct caging.
Recommended citation: 内田亮慈, 宇野健太朗, 吉田和哉. (2023). "インピーダンス制御を用いた双腕ロボットによる宇宙デブリ捕獲手法." 第41回日本ロボット学会学術講演会 (RSJ 2023).
Download Paper